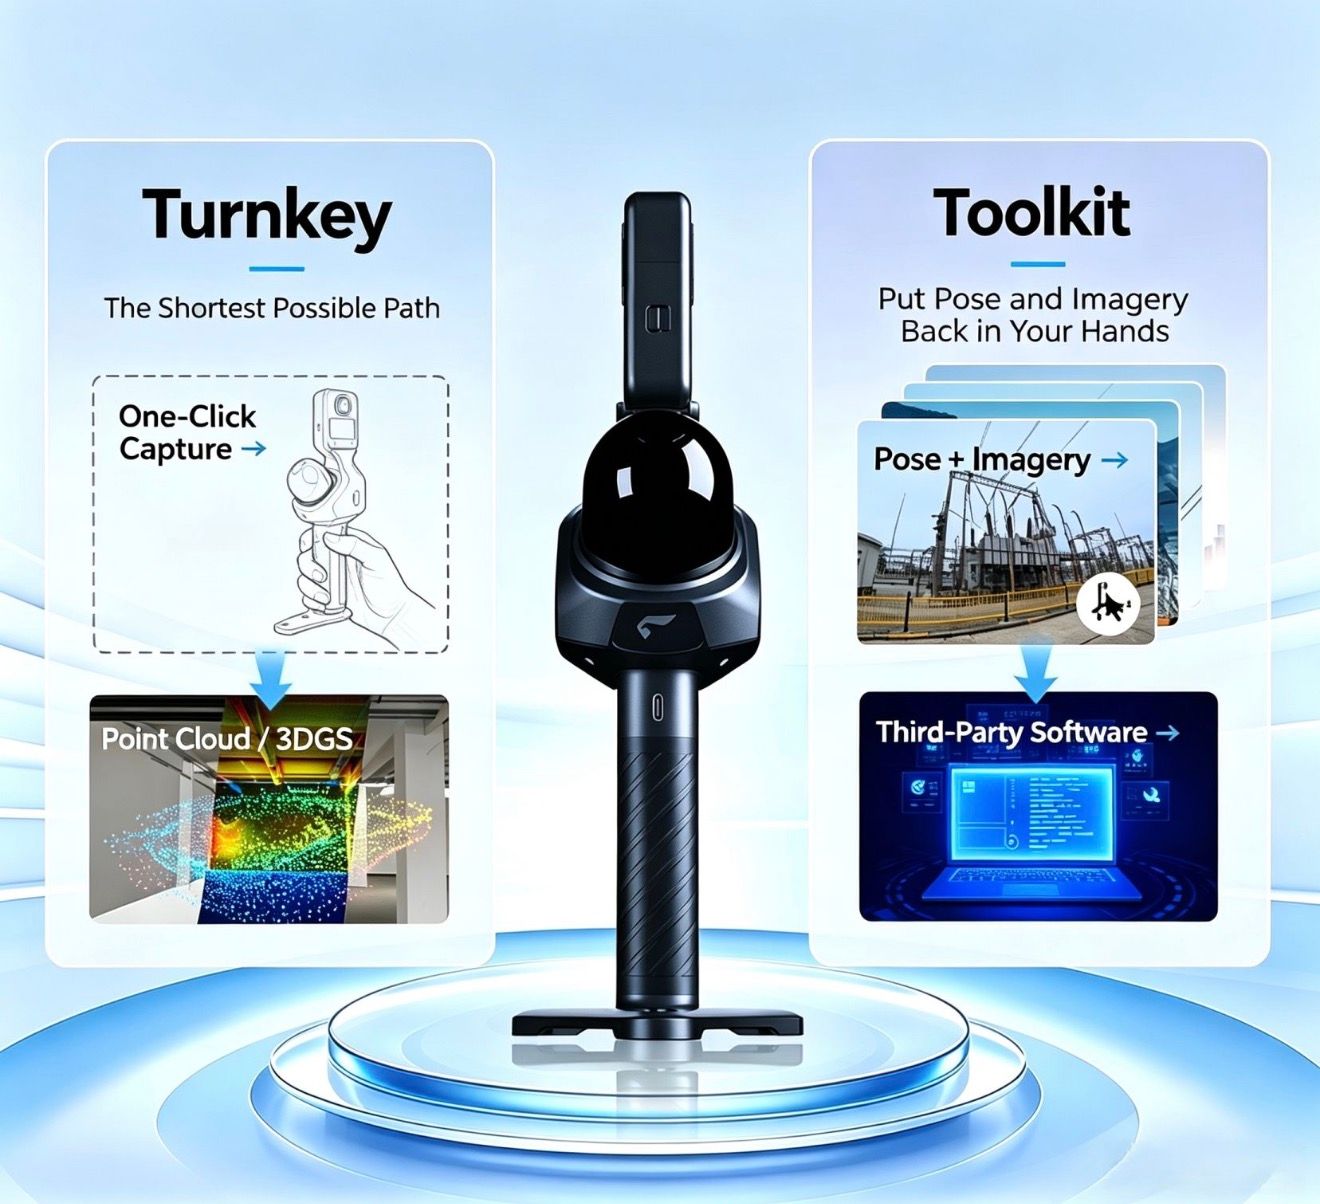
Feima Robotics Pocket3D: Portable 3D Reconstruction System
Pocket 3D is a compact handheld reality-capture system that combines a 16-channel LiDAR scanner with a panoramic camera. It records indoor and outdoor spaces as point clouds, panoramic images and 3D Gaussian Splatting (3DGS) models. The scanner weighs only 700 g without the camera, so one operator can carry it and scan with one hand. It captures 48,000 points per second over a range of up to 100 m. Relative accuracy is 2 cm at 60 m, and absolute accuracy is 5 cm under typical conditions.
The scanner is controlled from a phone with the SLAM GO app for iOS and Android. The app shows the point cloud live during scanning, so coverage can be checked on site. Pocket 3D works with the DJI Osmo 360 and the Insta360 X4, X4 Air and X5. The camera mounts without any cables, and the app starts and stops both devices together. A replaceable SP20 battery provides about 3 hours of runtime. The unit operates in temperatures from -20 °C to 50 °C, and all components pack into the supplied soft carry case.
User Guides
After scanning, the data is processed on a Windows computer with SLAM GO POST Pro. The software produces point clouds, colourised point clouds, panoramic images and 3DGS models. It also exports open data for third-party software, such as mesh modelling. Pocket 3D suits surveying and mapping, site documentation, visualisation and digital twins. The panoramic camera and a USB-C PD charger are not included, and the camera needs a one-time calibration before first use.
Bundled Software.
Pocket 3D works with two free companion applications. SLAM GO runs on a phone and controls the scanner in the field. SLAM GO POST runs on a Windows computer and processes the captured data.
SLAM GO POST (Windows)
Desktop software from Feima Robotics for processing Pocket 3D data. It produces colourised point clouds, panoramic images, odometry and 3DGS models, and exports data to third-party software for mesh modelling.
- System: 64-bit Windows 10 or 11, at least 50 GB free disk space
- CPU: x86_64 with AVX2 support (recommended: Intel 13th generation, 8 cores)
- GPU: NVIDIA only, CUDA driver 561.17 or higher (minimum RTX 2060; recommended RTX 4060)
- 3DGS: NVIDIA 30 series with 8 GB video memory minimum (RTX 5070 with 12 GB or more recommended)
- Memory: 16 GB minimum, 32 GB or more recommended
Stonex and 3rd party software
SLAM GO App (iOS and Android)
Mobile app that activates and controls the scanner, connects the panoramic camera and shows the point cloud live during scanning. It also records control points and supports firmware upgrades.
- iOS: iPhone 11 or newer, latest iOS, “Maximum Compatibility” turned on in Personal Hotspot
- Android: Android 10 or higher (Android 13 recommended), Snapdragon 865 or higher, 8 GB RAM, 64 GB storage
| Laser Scan Performance | System Specification | ||
| Maximum range | 100 metres | Storage | 64 GB TF (microSD) card supplied, supports up to 256 GB |
| Minimum range | 0.15 metres | Control | SLAM GO app (Android/iOS) or onboard button |
| Range at 10% reflectivity | 30 metres | Communication | Wi-Fi, Bluetooth, USB-C |
| Relative accuracy | 2 cm at 60 m | Processing software | SLAM GO POST Pro (Windows) |
| Absolute accuracy | 5 cm (typical conditions) | Mounting | 1/4-inch threaded hole on the base |
| LiDAR channels | 16 | ||
| Points per second | 48,000 | Power Specification | |
| Scan frequency | 10 Hz | Power consumption | 7 Watts |
| Field of view | 360° horizontal × 40° vertical | Operating time | Approx. 3 hours per battery |
| Battery | SP20 intelligent battery handle, replaceable | ||
| Camera Performance | Capacity | 2450 mAh | |
| Cameras | External panoramic camera (not included) | Charging | USB-C PD, 20 V, 30 W or higher recommended (charger not included) |
| Supported cameras | DJI Osmo 360; Insta360 X4, X4 Air, X5 | ||
| Camera connection | Wireless control via SLAM GO app, no cable required | Physical Specs. | |
| Camera setup | One-time calibration required | Weight | 700 g (without camera) |
| Point cloud colouring | Post-processing in SLAM GO POST Pro | Size | 127 mm × 105 mm × 223 mm |
| Operating temp. | –20°C to +50°C | ||
| Operating humidity | < 95% relative humidity |
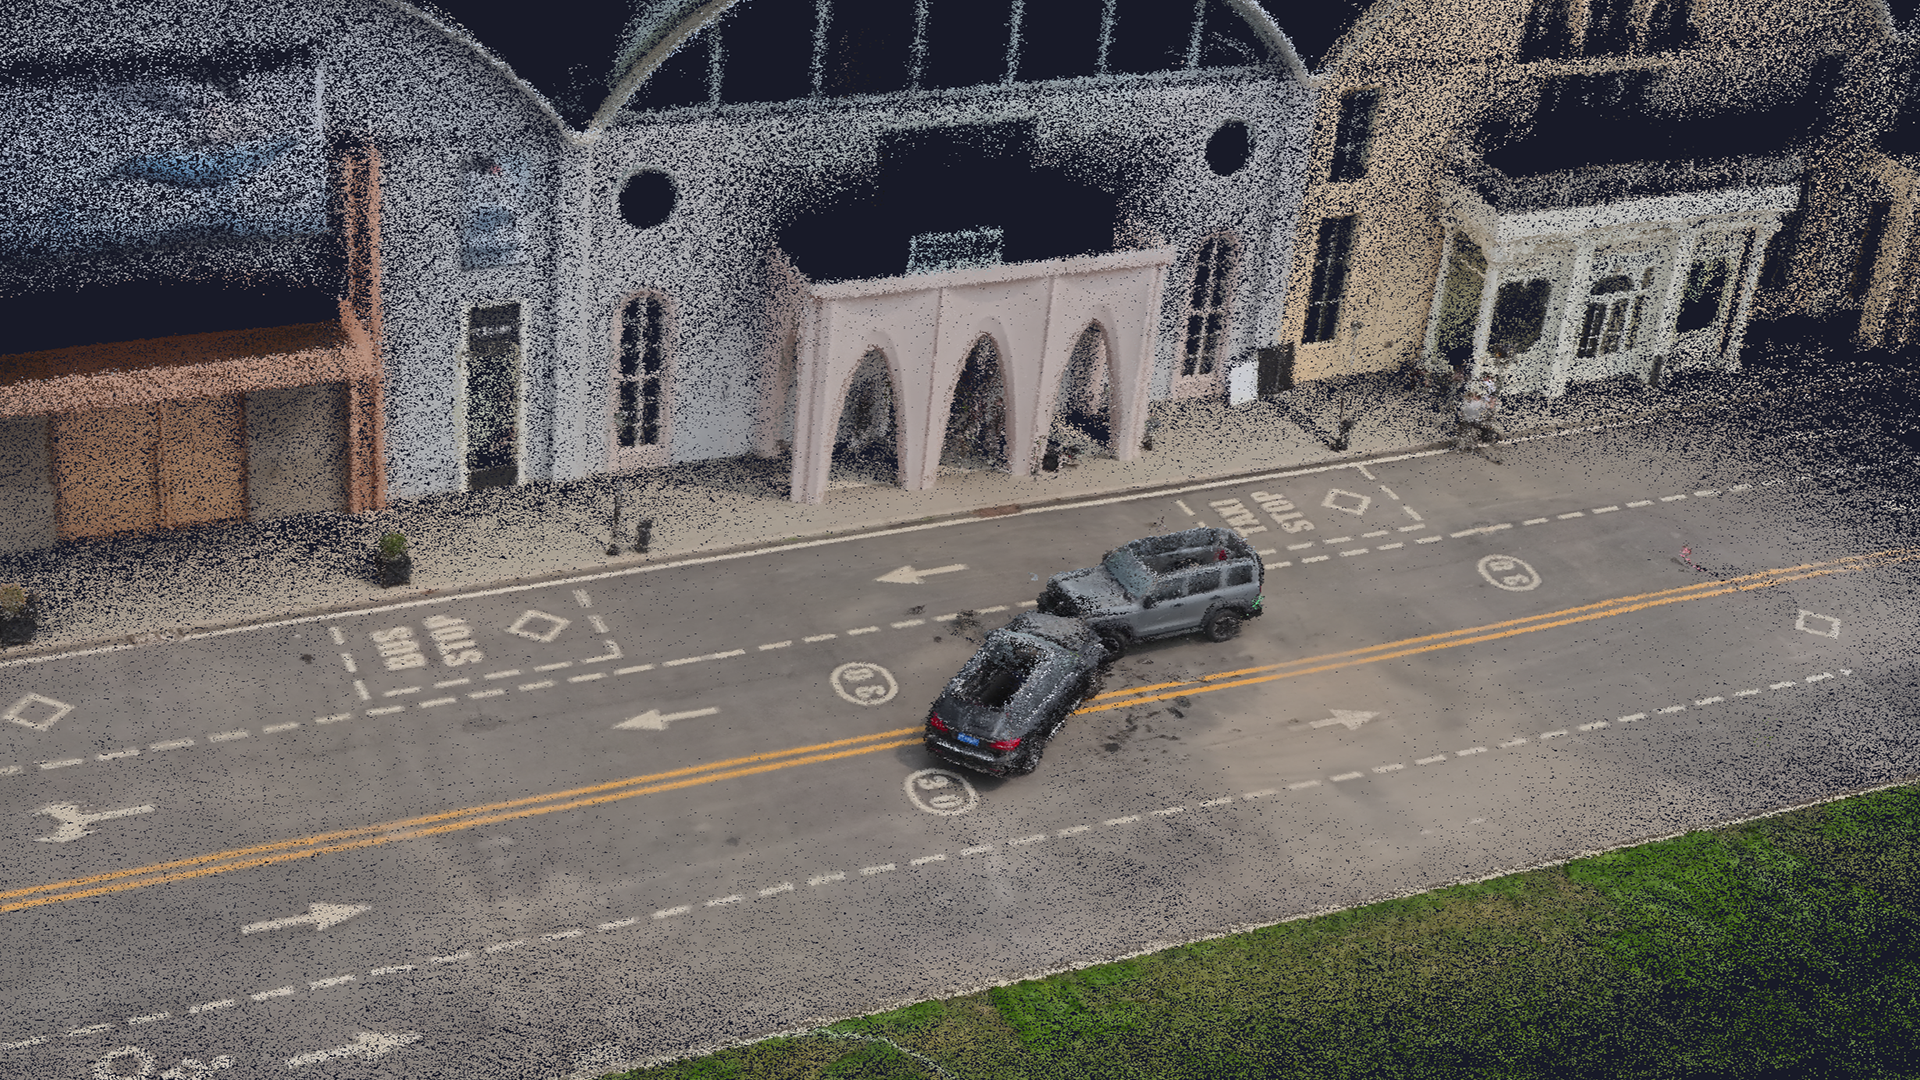
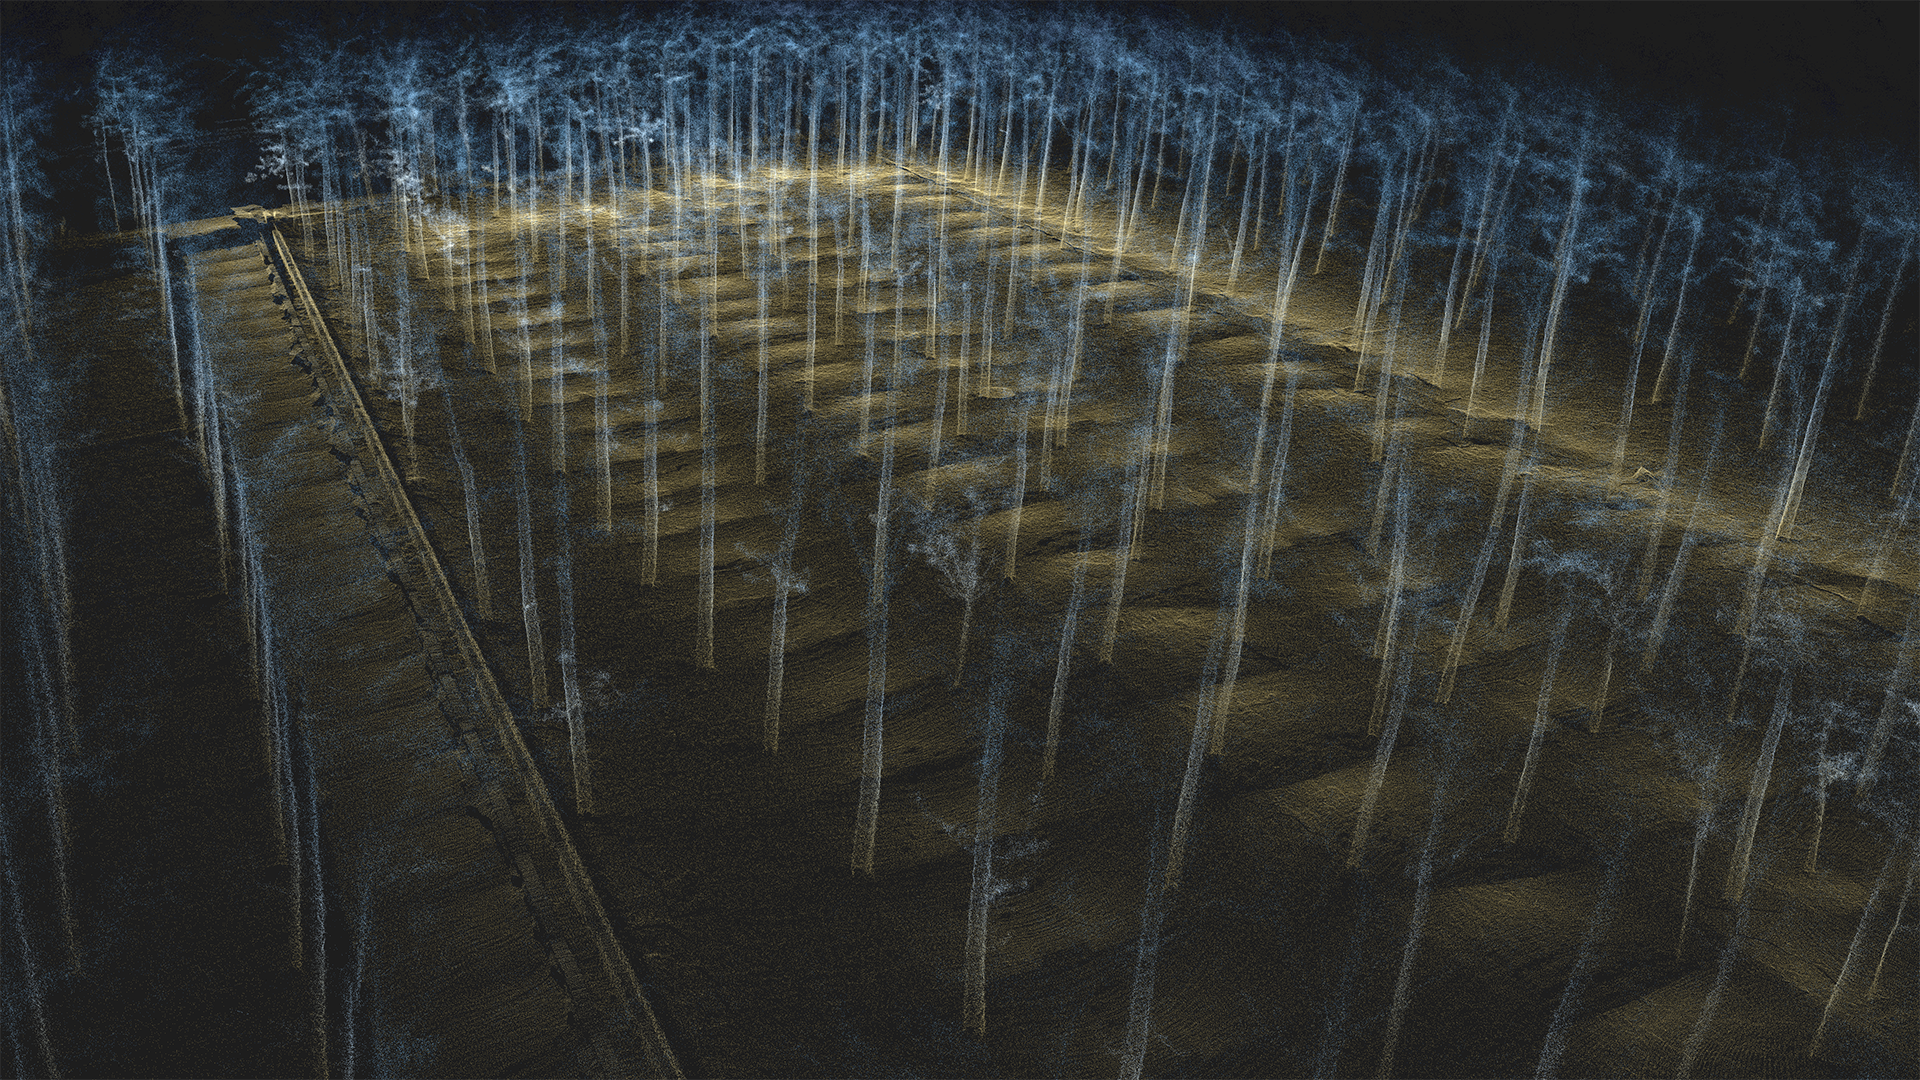
Point Clouds Captured with the Poket 3D
Gaussian Splat Examples from thePoket 3D
The Feima Robotics Pocket 3D supports a streamlined 3D visualisation workflow by creating Gaussian Splat models directly from its SLAM-based point-cloud data. When paired with a DJI Osmo 360 or an Insta360 X4, X4 Air or X5 panoramic camera (purchased separately), the scanner produces immersive, photorealistic 3D scenes suited to digital twins, site documentation and visual inspection.
The workflow is completed entirely within the SLAM GO POST Pro software, with no third-party software required:
- Capture the SLAM point cloud with the Pocket 3D while the mounted panoramic camera records 360° imagery
- Copy the scan project and camera recording to a Windows computer
- Train and generate the Gaussian Splat model directly in SLAM GO POST Pro using One-click Solve
- Review the final splat in the built-in 3DGS viewer
The result is a highly realistic, spatially accurate 3D representation that combines SLAM-derived geometry with rich panoramic imagery. Processing requires a Windows computer with an NVIDIA graphics card, and the one-time camera calibration must be completed before the first scan. Below are several Gaussian Splat examples produced with the Pocket 3D, showing the visual quality achievable with this workflow.
Price: $2,480 ex GST
Included in the price:
- Pocket 3D scanner body
- SP20 intelligent battery handle and base
- 64 GB TF (microSD) card (pre-installed)
- Camera mounting hardware
- USB SD/microSD card reader
- Wrench set and extra magnetic circle
- Charging cable
- Soft carry case
- Quick Start Guide
- Inspection certificate
- SLAM GO mobile app and SLAM GO POST Pro desktop software
Not included: panoramic camera (DJI Osmo 360 or Insta360 X4, X4 Air, X5) and a USB-C PD charger (20 V, 30 W or higher recommended).