Stonex X200Go SLAM LiDAR
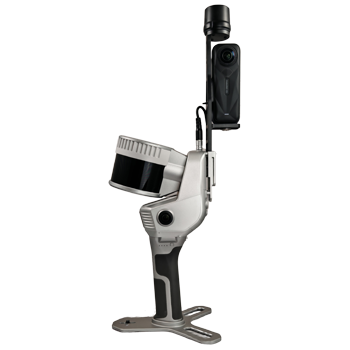
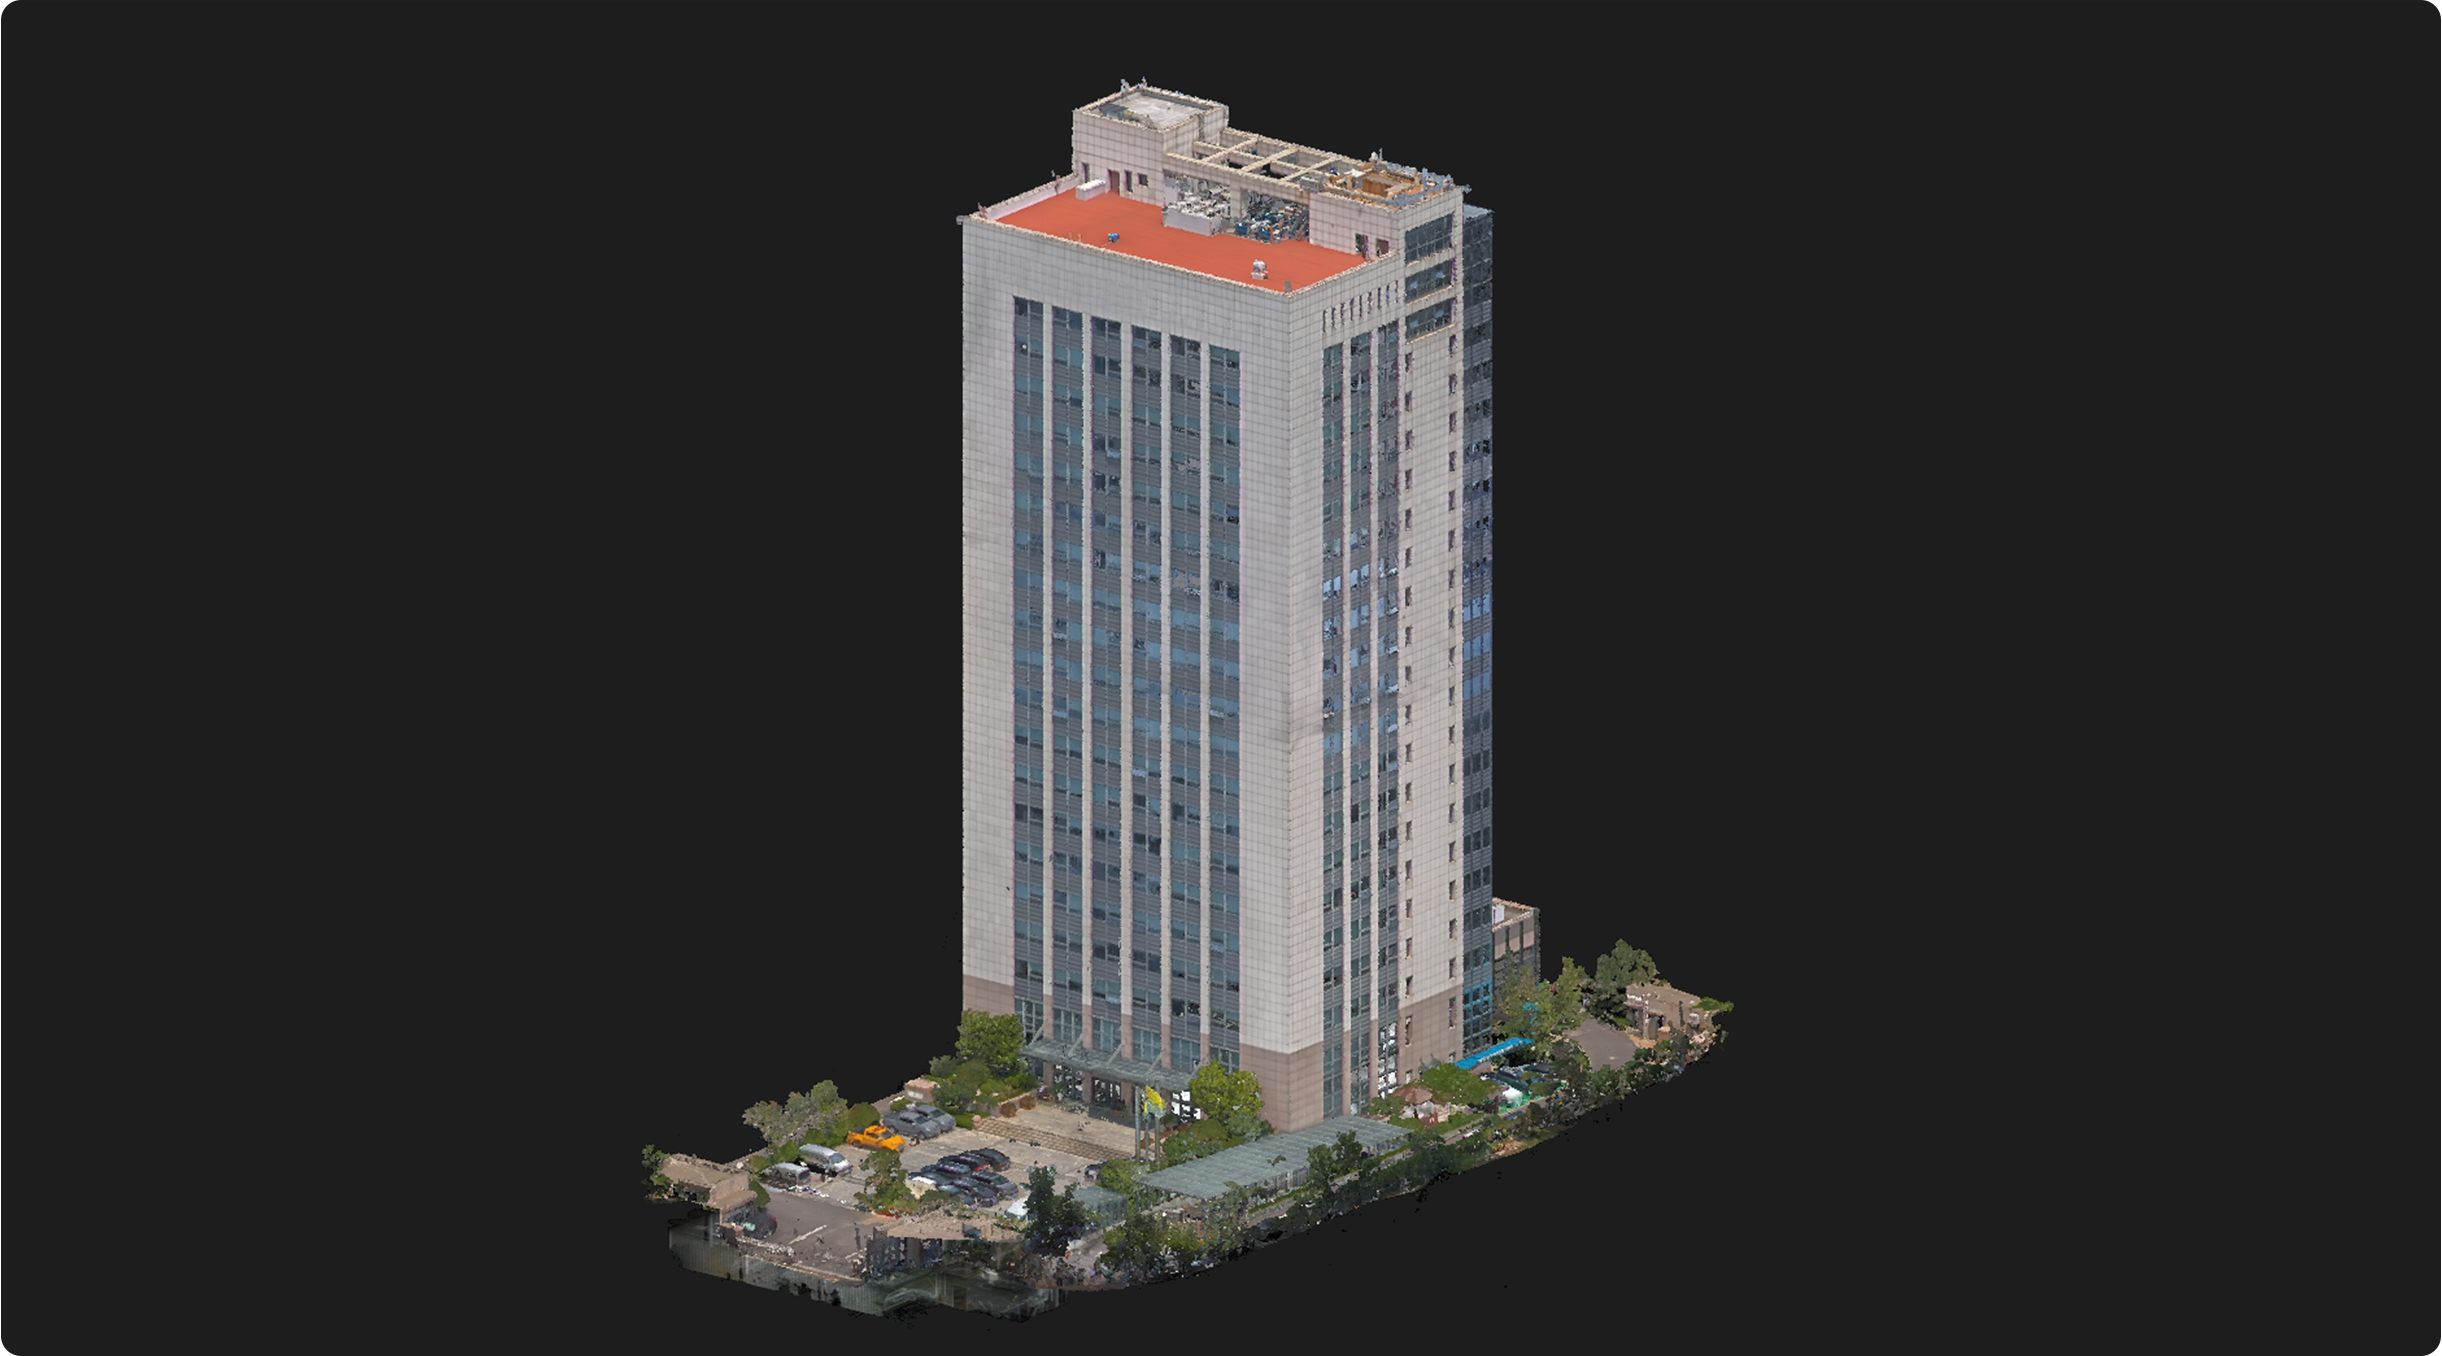
The Feima Robotics SLAM200 and SLAM200E are high-performance handheld laser scanners powered by SLAM technology, designed to deliver fast, accurate and georeferenced 3D data in both indoor and outdoor environments. The SLAM200 reaches a scanning distance of up to 300 m, with built-in RTK and built-in panoramic cameras, while the SLAM200E offers a range of up to 120 m. The SLAM200E combines a high-frequency LiDAR sensor, dual 12 MP panoramic cameras, a built-in high-precision GNSS module and an onboard computing unit, enabling real-time acquisition, mapping and colouring. The panoramic imagery supports point cloud colouring, panorama generation, 3D reconstruction and 3D Gaussian Splatting (3DGS).
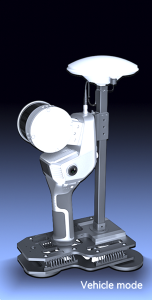
A standout feature of both scanners is the static scanning mode, which removes motion-induced errors from handheld scanning and produces dense, high-fidelity point clouds in challenging locations. This makes them well suited to documenting construction sites, architectural spaces, industrial facilities and cultural heritage assets. The SLAM200E also achieves relative accuracy of 5 mm within 60 m, and absolute accuracy of up to 2 cm when connected to an external RTK module or combined with ground control points. Several mounting options provide flexibility for mobile and aerial scanning: backpack mode, extension pole mode, vehicle-mounted mode and a UAV-mounted mode compatible with DJI drones. A smart battery handle and external power supply support long scanning sessions.
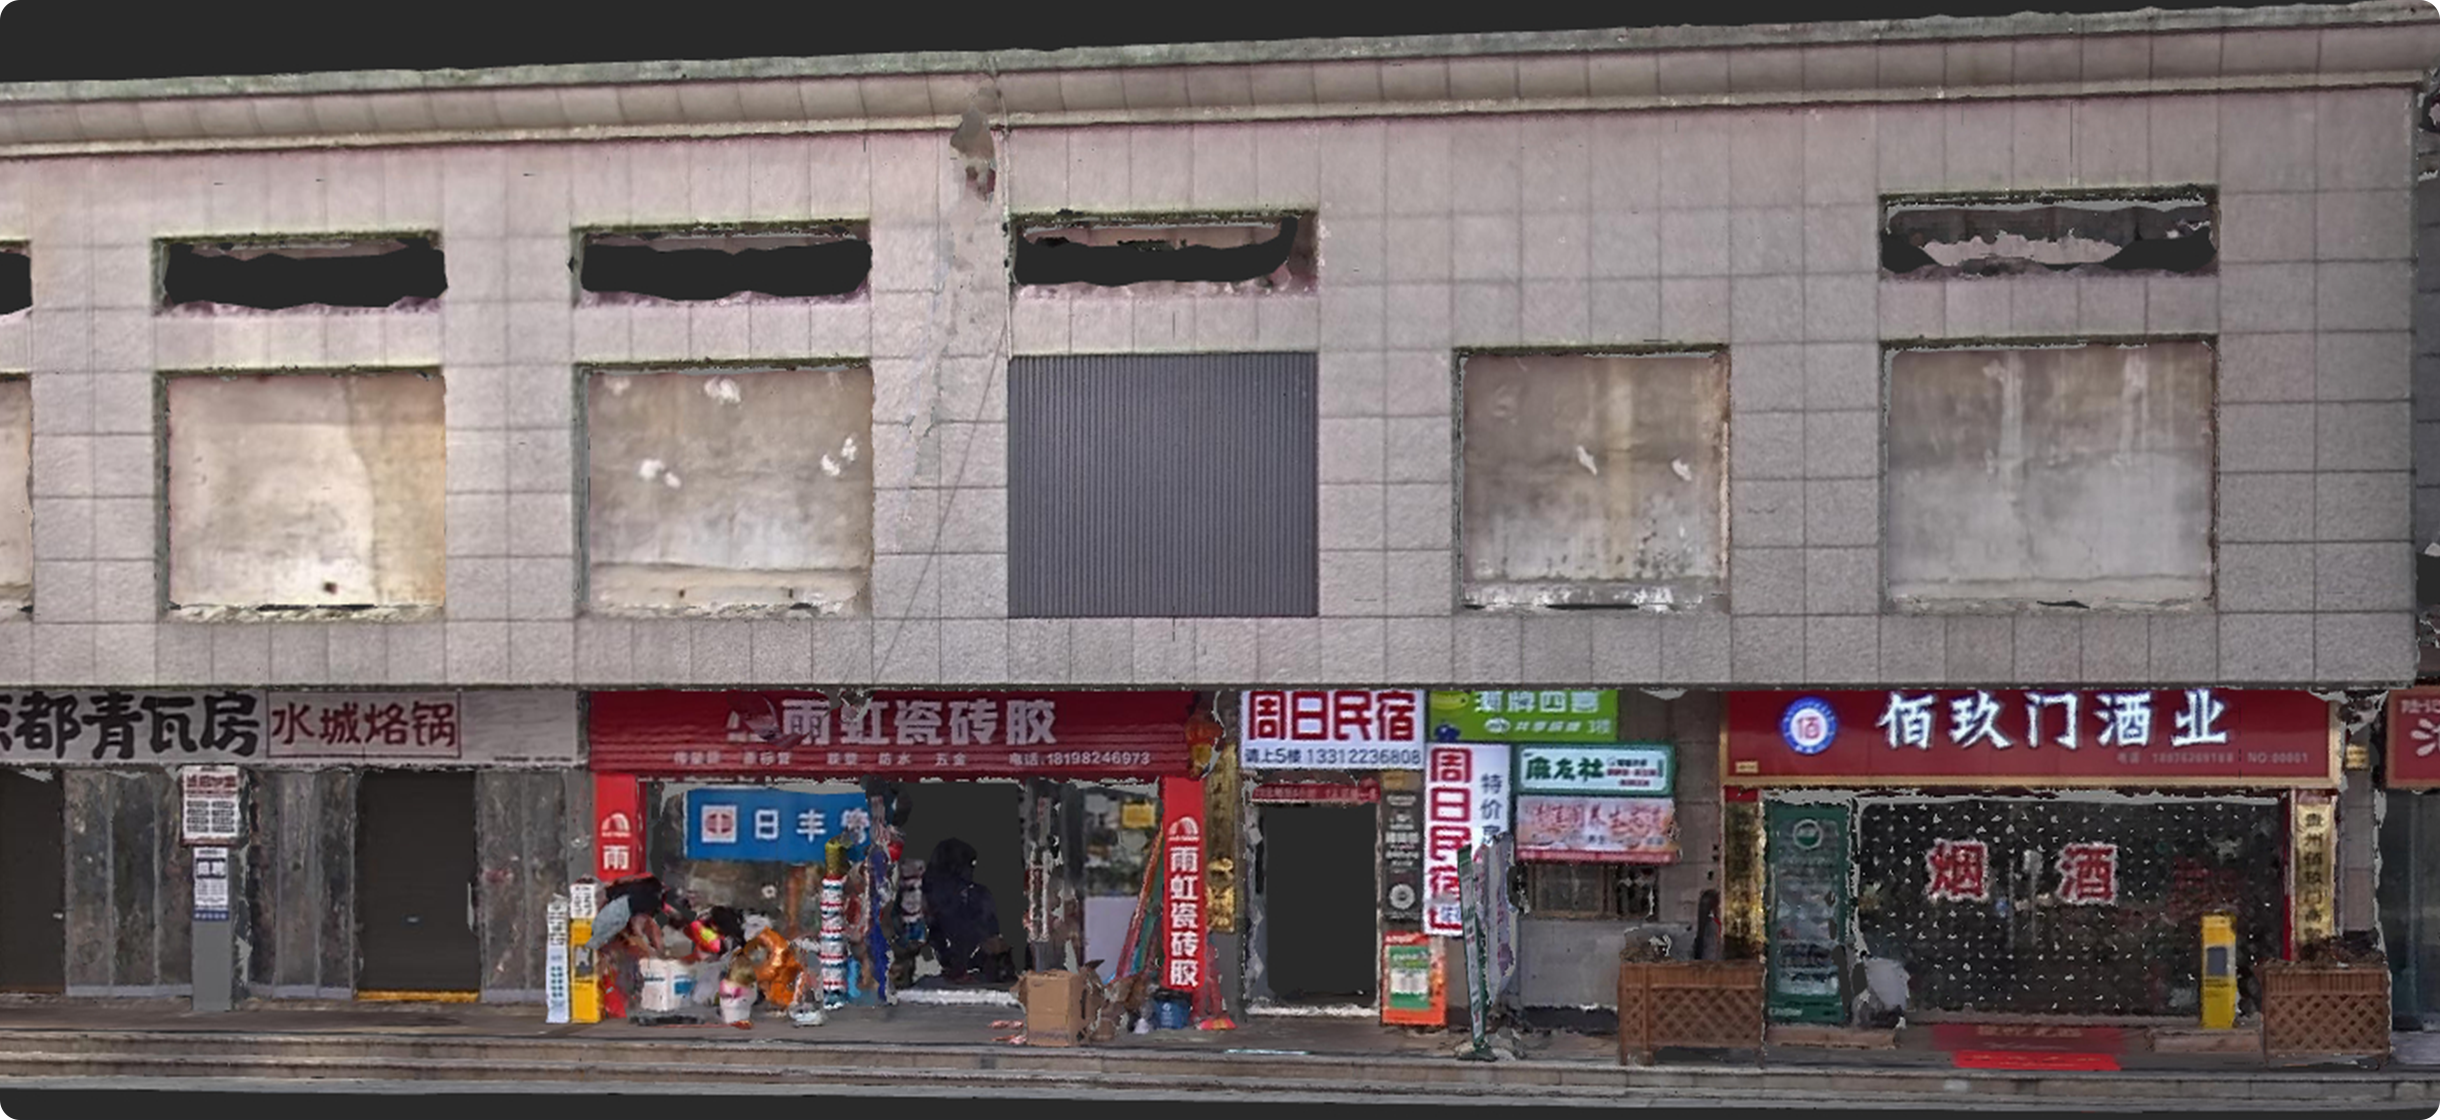
Data captured by the SLAM200 and SLAM200E is processed with Feima’s SLAM GO POST Pro software into high-resolution colourised point clouds, panoramic images and 3DGS models. Outputs and intermediate data use open formats, so they work with third-party platforms for mesh production, BIM workflows, inspection and digital twin creation. The SLAM200E is also supported by the SLAM Instant app, which provides instant measurements and on-site reports within minutes of capture. Whether navigating tight corridors or scanning expansive outdoor areas, the SLAM200 and SLAM200E deliver reliable, high-speed 3D mapping with minimal setup and maximum mobility
The SLAM 200 Standard package is $45,000 exGST and includes:
• Hard shell protective case
• Handle with internal lithium-ion battery
• Mounting base compatible with multiple configurations
(backpack, shoulder hook, vehicle, and drone)
• AC wall charger and power cable
• GO App for Android tablet
• GOpost software and USB dongle for data processing
• Calibration test report
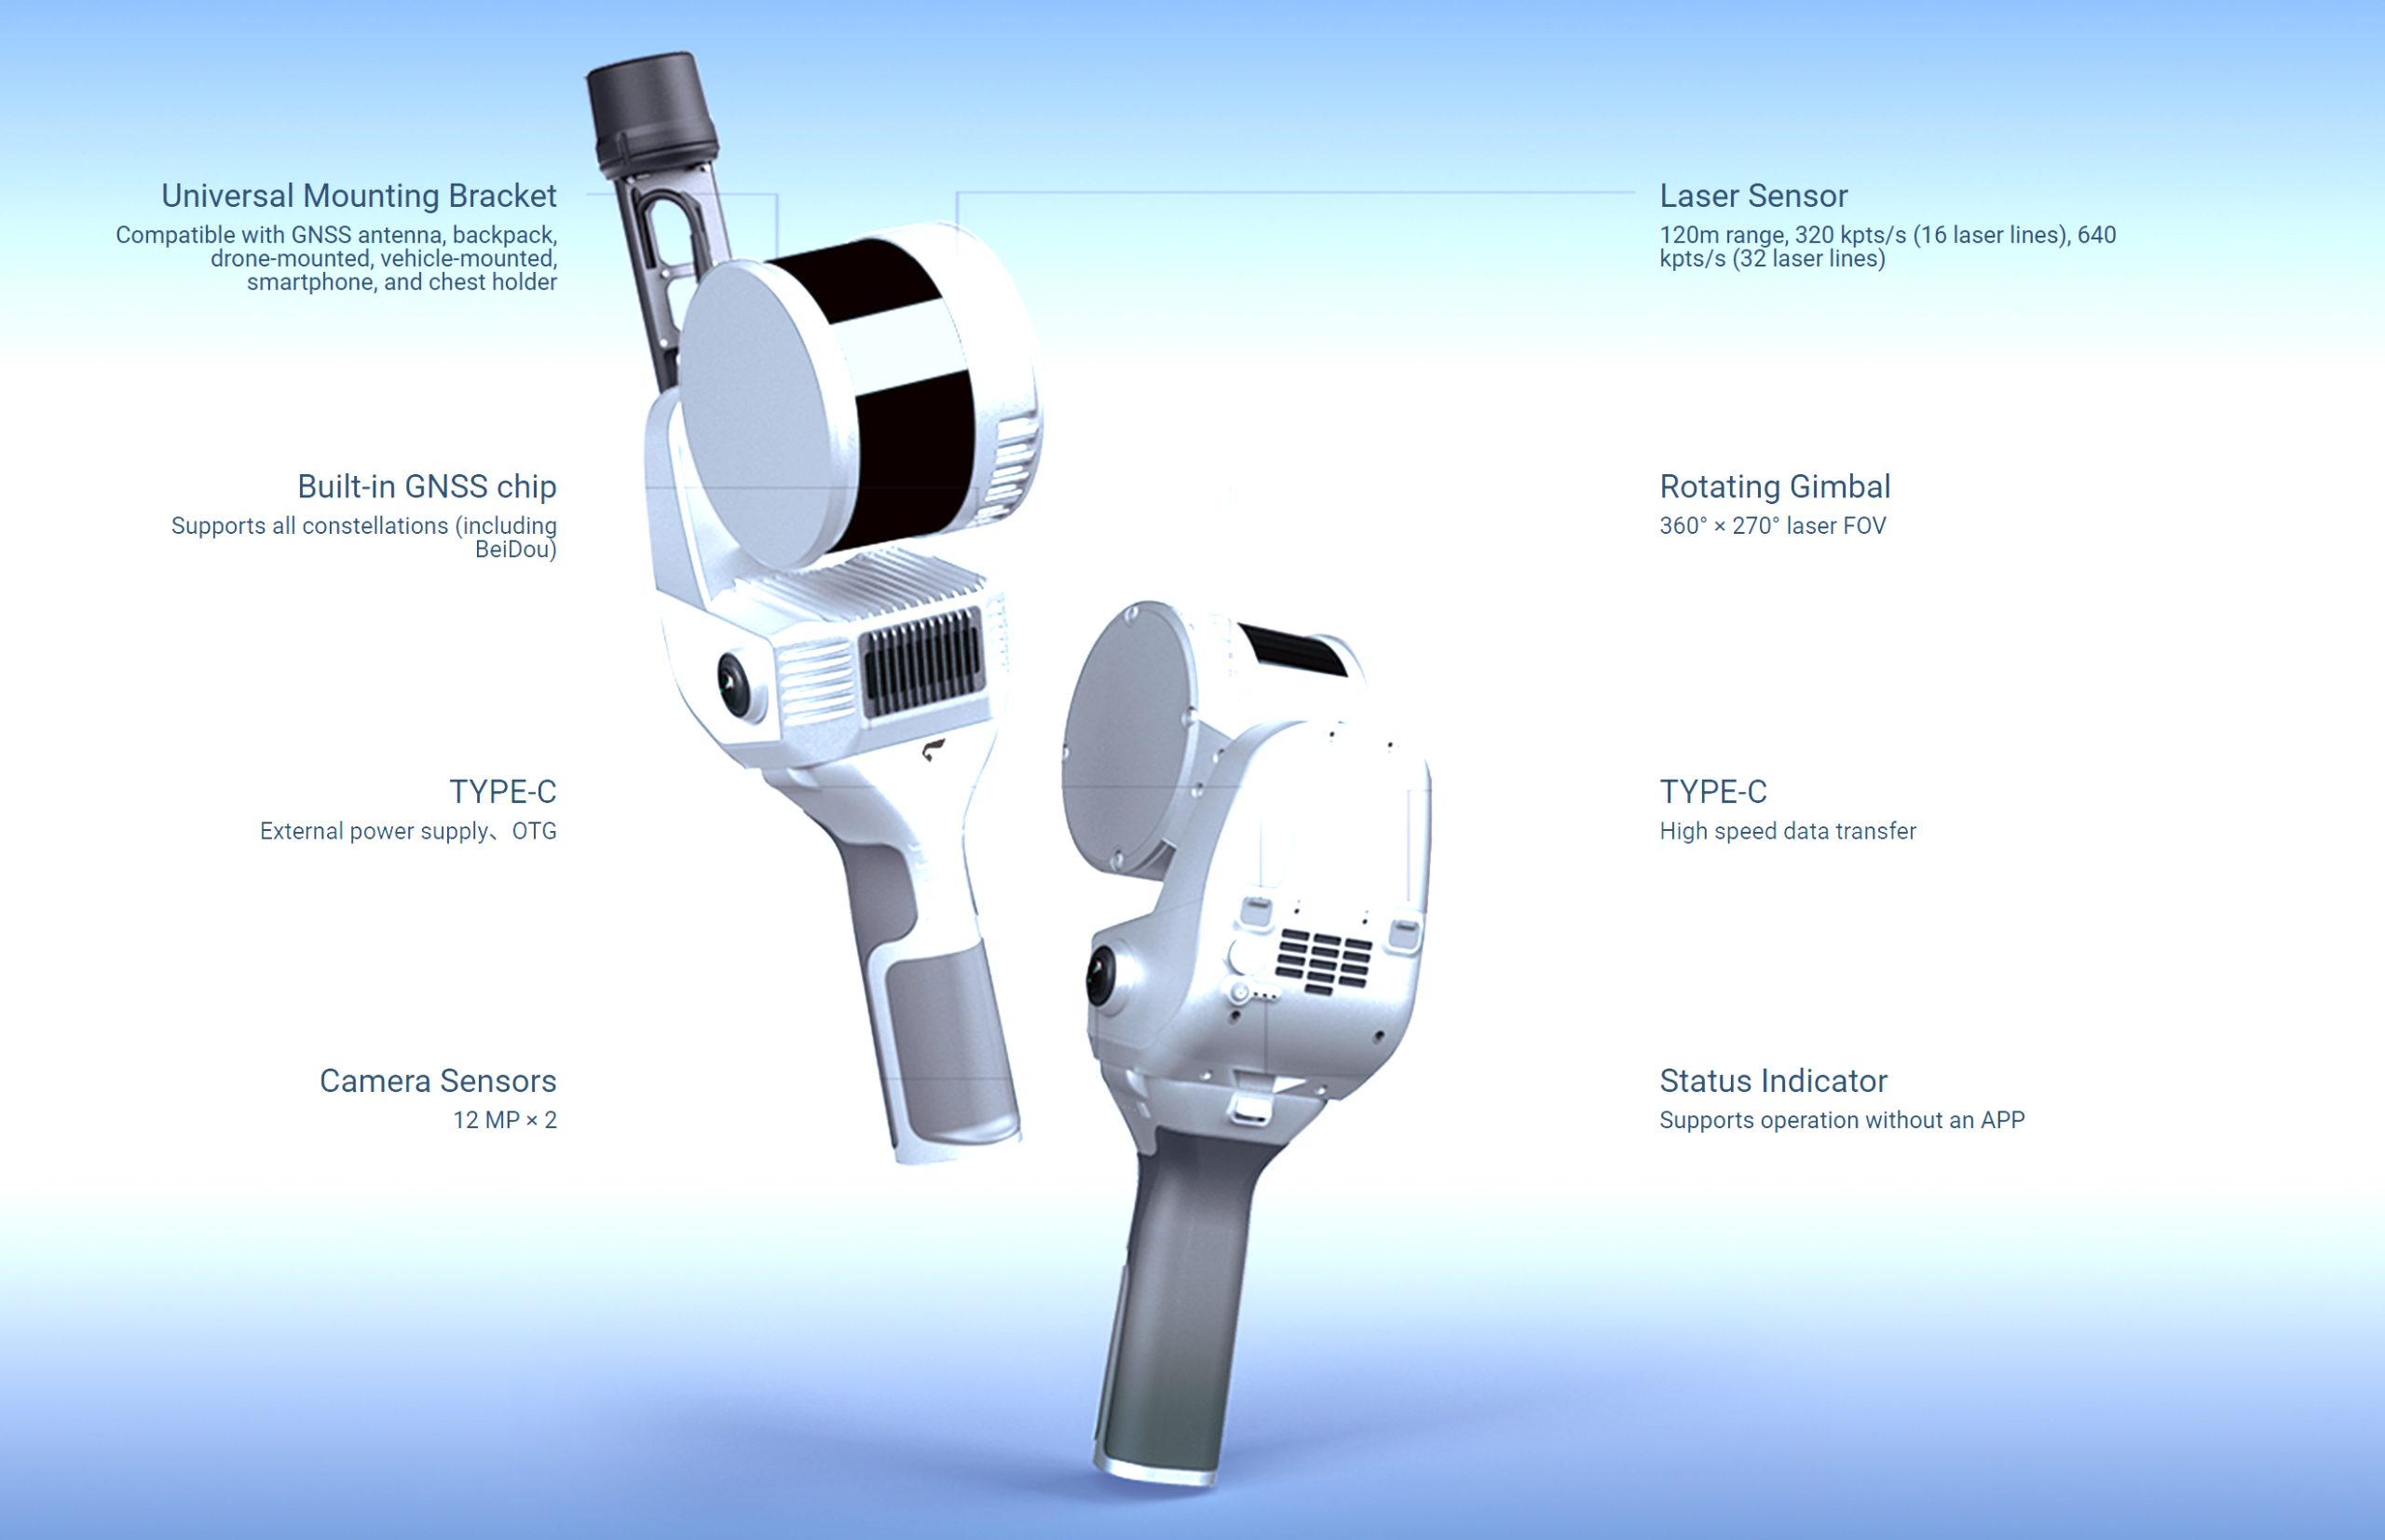
The Feima Robotics SLAM200 and SLAM200E feature dual high-resolution panoramic cameras that work together with the LiDAR sensor to capture colourised point clouds and immersive panoramic images. The SLAM200E uses dual 12 MP cameras with a 360-degree field of view, and the imagery supports point cloud colouring, panorama generation, 3D reconstruction and 3DGS. Combining LiDAR geometry with this imagery produces lifelike, spatially accurate 3D models.
This versatile SLAM-based scanner is ideal for dynamic 3D mapping across indoor and outdoor environments, including GNSS-denied sites. It offers handheld SLAM scanning alongside a static scanning mode, which removes motion-induced errors and delivers denser, higher-fidelity point clouds. The SLAM200 has built-in RTK for georeferenced capture, and when the SLAM200E is connected to RTK, it outputs point clouds with absolute coordinates in real time.
Accessories if required
Battery handle is $750 exGST
Tablet holder is $270 exGST
Shoulder hook to support the X200Go when walking is $1,000 exGST
Backpack frame bundle is $2,400 exGST
Vehicle mount bundle is $4,150 exGST
UAV platform to suit DJI M350 is $1,200 exGST
Bundled Software Ecosystem
- SLAM GO (Android & iOS):
A mobile app that controls the scanner, collects point cloud data and shows results in real time. It also handles firmware upgrades from the cloud, giving reliable field operation and immediate feedback during capture. - SLAM GO POST (Windows):
A desktop post-processing tool that refines scan data and produces colourised point clouds, high-resolution panoramic images, optimised odometry and 3DGS models. Ground control points can be integrated for georeferencing, and outputs use open formats for use with third-party software. - SLAM Instant app (SLAM200E):
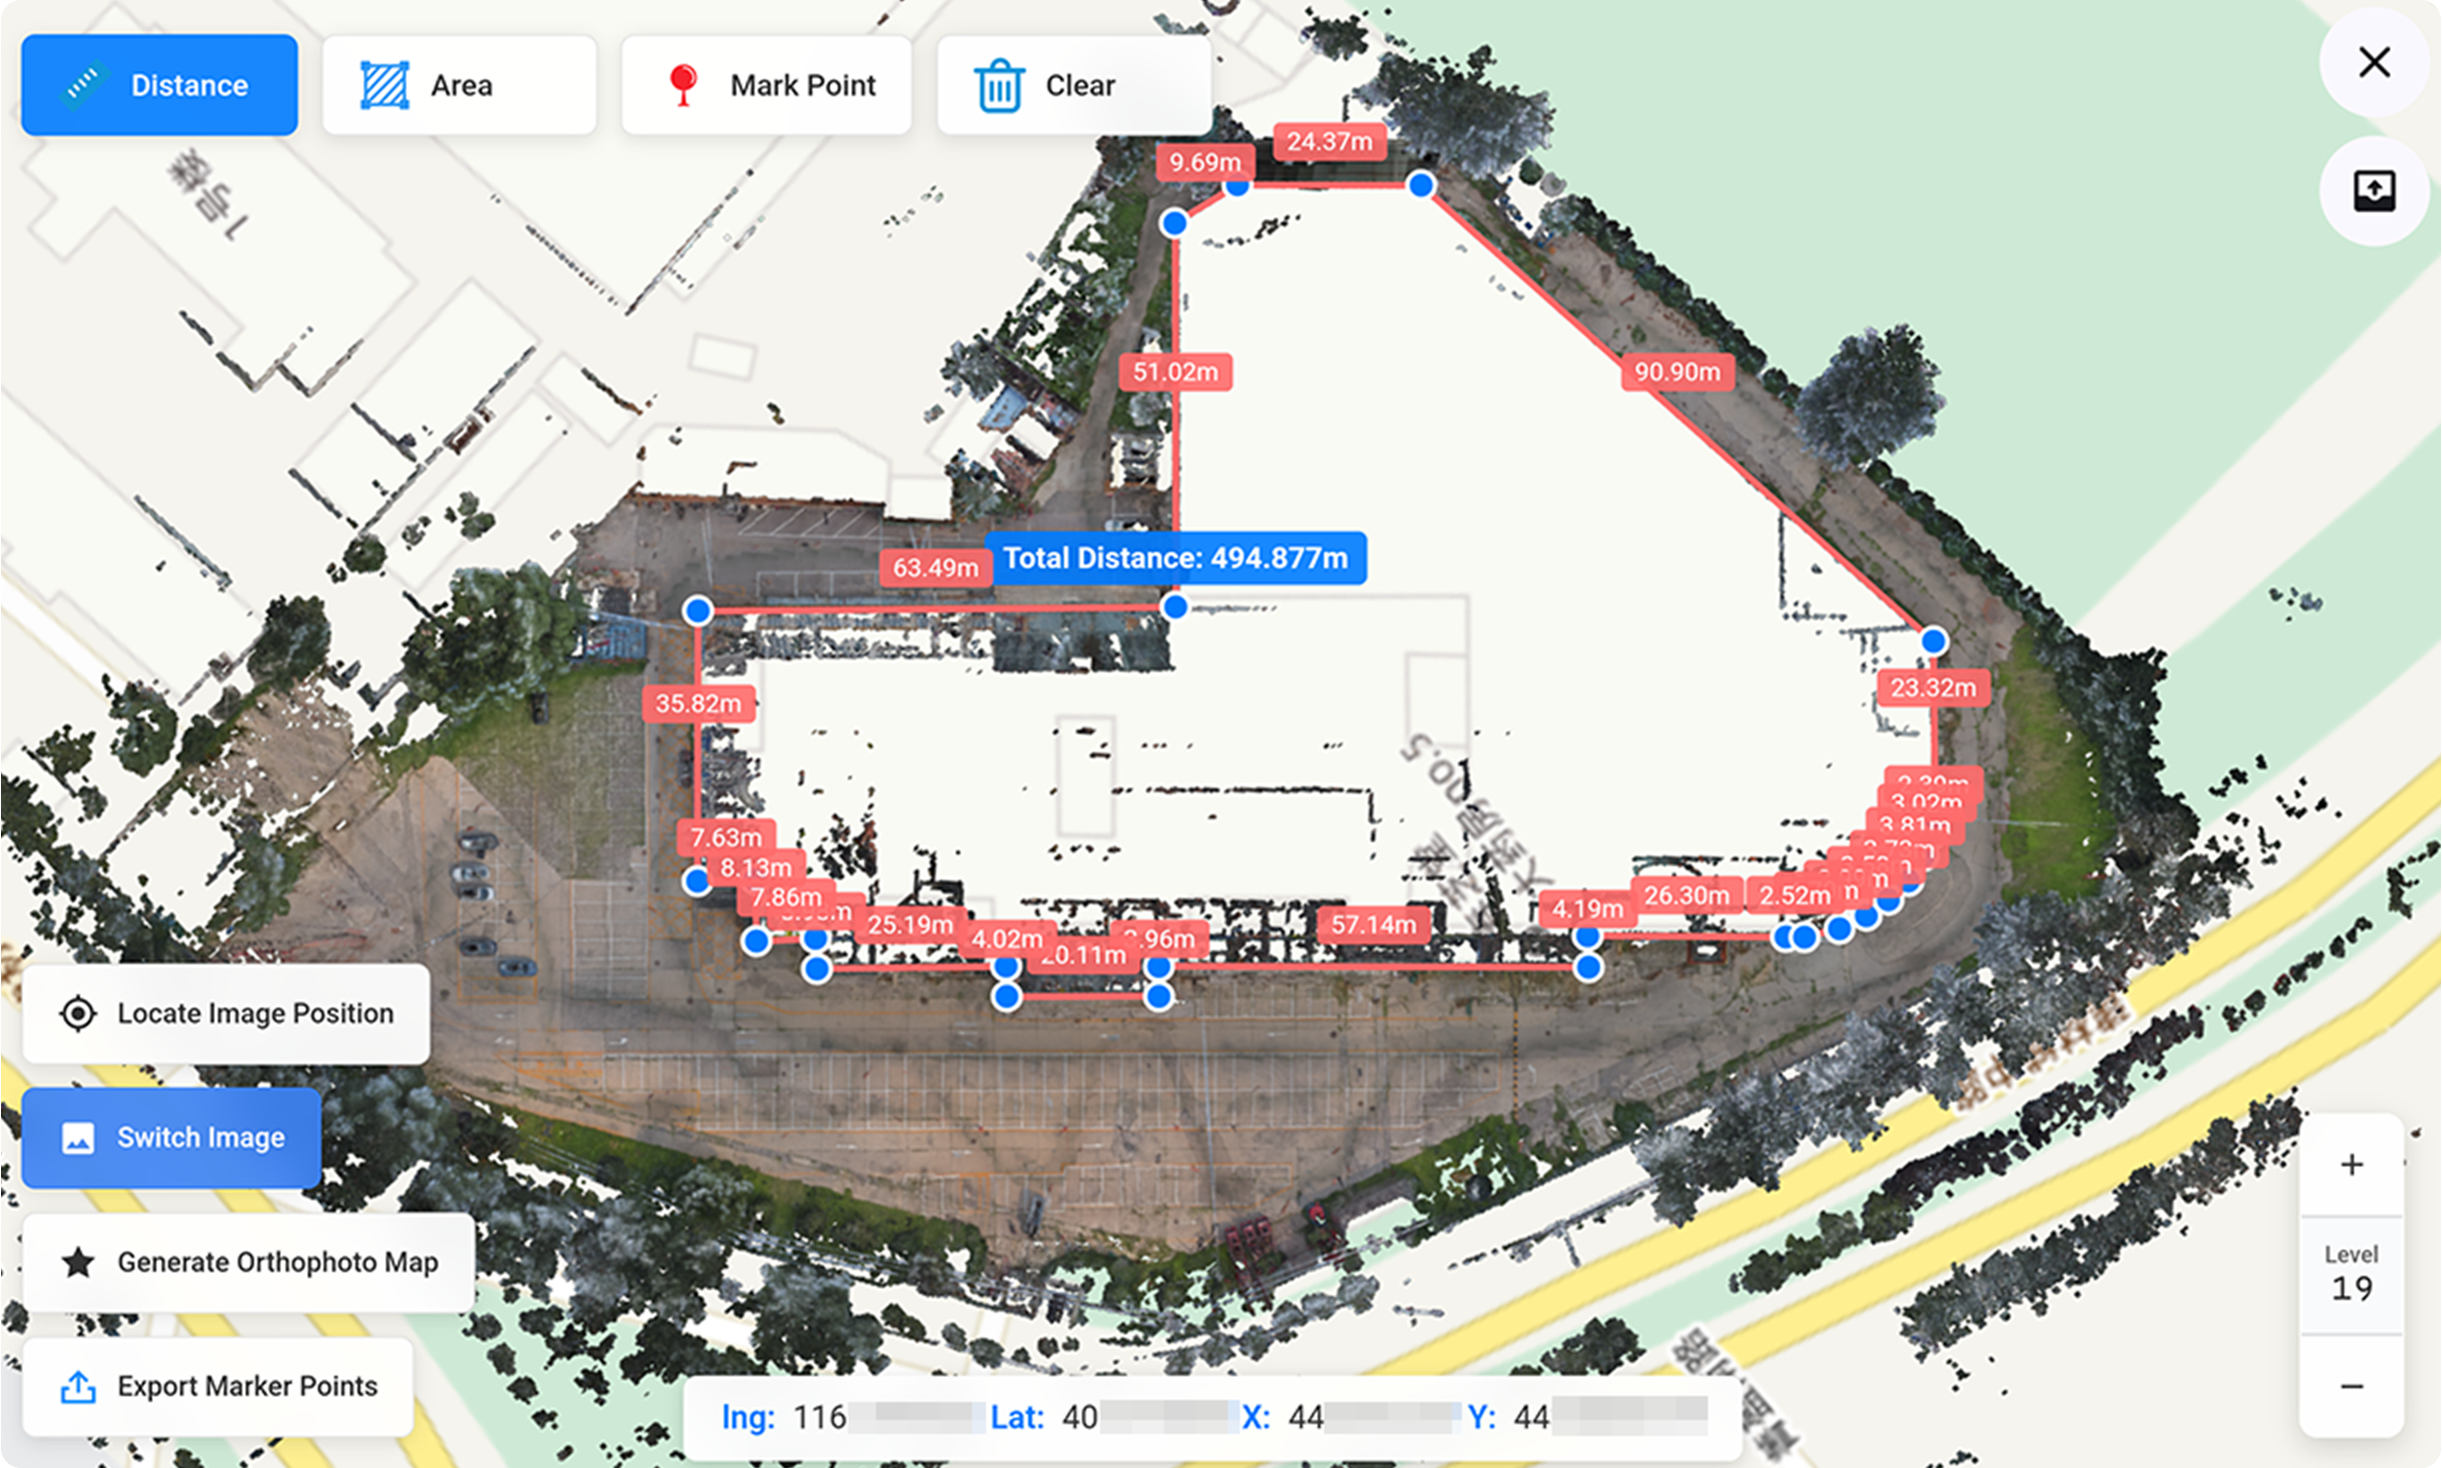
A mobile app for instant mapping after measurement, fast capture of points, lines, areas and volumes, and industry-ready reports generated on site. The SLAM200E can also stream mapping results in real time over LAN or the internet, so teams can view them remotely from a PC.
Key Advantages
- Static Scanning Mode:
Eliminates motion-induced errors by scanning from fixed stations. The field of view can be defined, and static-station datasets are registered and optimised automatically. This adds high-density detail to areas where fine accuracy matters. - Rapid Data Collection:
Eliminates the need for multiple setups. Walking through the environment captures a complete 3D point cloud, with real-time mapping and real-time colouring. - Real-Time Results:
A high-frequency LiDAR sensor and a high-performance onboard computing unit enable real-time acquisition, mapping and colouring. This gives stable performance on GNSS-denied sites, with data ready straight after the survey. - Accurate Georeferencing:
The SLAM200 has built-in RTK. The SLAM200E can reach absolute accuracy of up to 2 cm when connected to an external RTK module or combined with ground control points. - Flexible Mounting Options:
Backpack, extension pole, vehicle-mounted and UAV-mounted modes (compatible with DJI drones), plus external power supply, let the SLAM200 and SLAM200E adapt to diverse surveying scenarios.
Whether scanning architectural interiors, construction sites or outdoor landscapes, the SLAM200 and SLAM200E offer a powerful, efficient and user-friendly solution for creating high-quality 3D models.
| Stonex X200GO | Specifications |
|---|---|
| LIDAR | |
| Sensor Model | Hesai XT32M2X |
| Max Range | 300 m |
| Min Range | 0.5 m |
| Return Number | 3 |
| Single Return Rate | 640,000 pts/s |
| Scanning Frequency | Not specified |
| Field of View | 360° x 290° |
| Laser Class | 1 |
| Channels | 32 |
| Wavelength | 905 nm |
| Color Camera | |
| Number of Pixels | 24 MPx (2 cameras, 12 MPx each) |
| Diagonal FOV | 210° |
| Focal Length | 1.26 mm |
| Resolution | 4000 x 3000 px |
| Sensor Size | 1/2.3 inch |
| Pixel Size | 1.55 µm |
| GNSS Receiver | |
| Satellite Signals | GPS L1 C/A/L2P(Y)/L2C/L5, GLONASS G1/G2, Galileo E1/E5A/E5B, BDS B1I/B2I/B3I, QZSS L1/L2/L5 |
| DGPS Accuracy (RMS) | Horizon: 0.4 m + 1 ppm; Vertical: 0.8 m + 1 ppm |
| RTK Accuracy (RMS) | Horizon: 0.8 cm + 1 ppm; Vertical: 1.5 cm + 1 ppm |
| Speed Accuracy (RMS) | 0.03 m/s |
| System | |
| Relative Accuracy | Up to 6 mm |
| Global Accuracy | Up to 2 cm; 5 cm on UAV platform |
| Control Point Support | Ground & wall |
| Data Storage | 512 GB SSD |
| Communication | Wi-Fi, Bluetooth, USB Type-C, Lemo connector |
| Operating Modes | SLAM & X-Whizz modes |
| Processing Modes | GoPost Post-processing of data for visualization, coloring, and orientation |
| Electrical Specs | |
| Power Consumption | 26 W |
| System Supply Voltage | 20 V |
| Operating Time | 3.2 h (single battery) |
| External Power | USB Type-C |
| Battery Input Voltage | 5–20 V |
| Battery Output Voltage | 10.8 V |
| Battery Capacity | 3000 mAh |
| Physical Specs | |
| Weight | 1.4 kg (without battery); 1.9 kg (with battery) |
| Dimensions | 403.6 mm x 173.8 mm x 170 mm |
| Operating Temperature | -20°C to +50°C (-4°F to 122°F) |
| Operating Humidity | <95% |
| Waterproof/Dustproof | IP54 |
SLAM Instant APP Volume Measurement Process
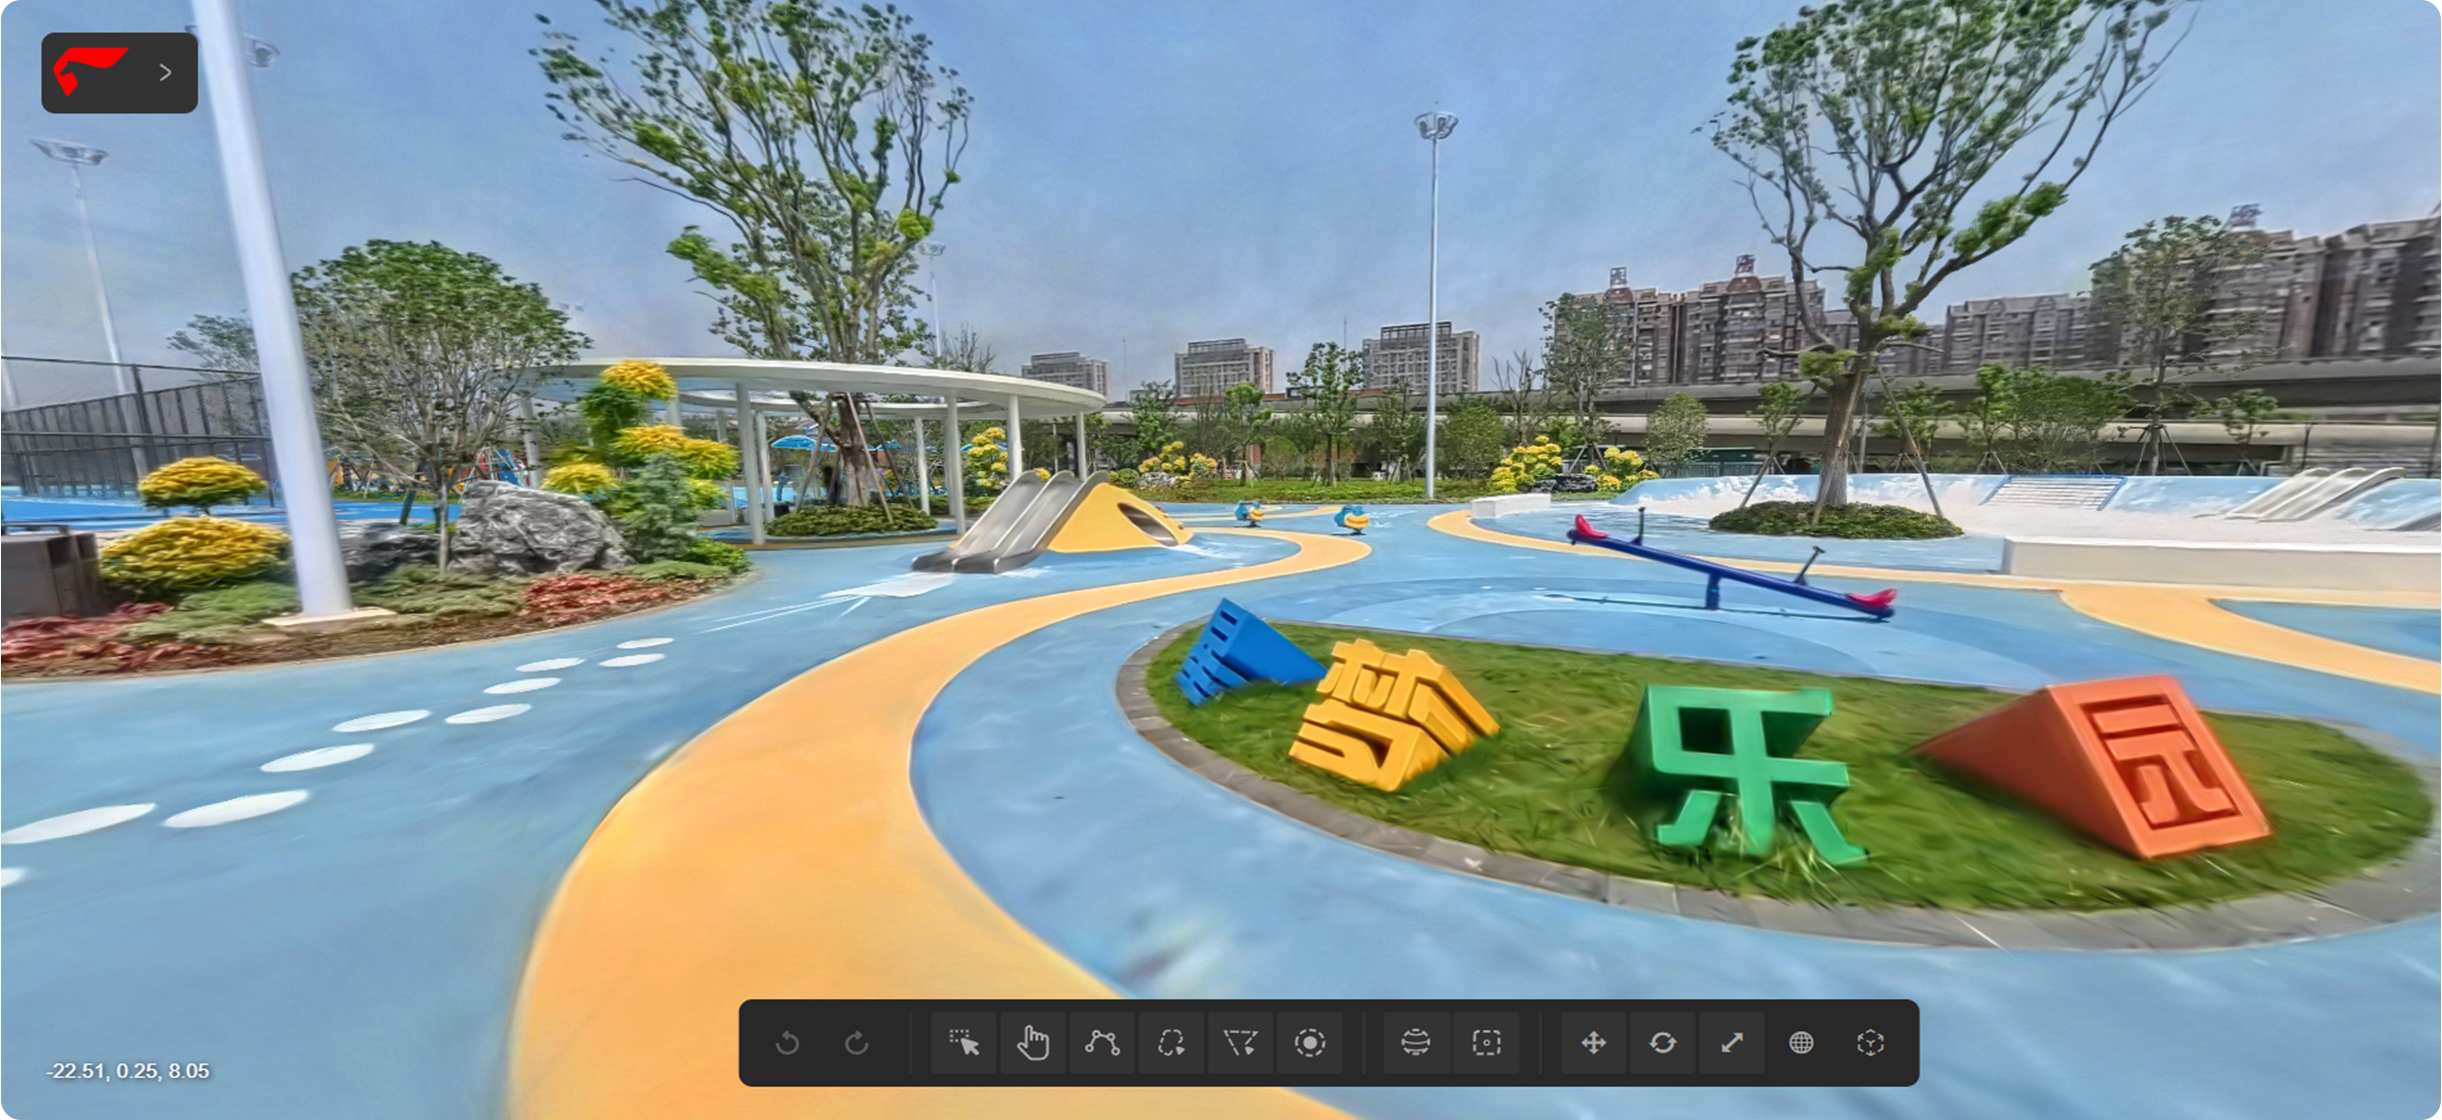
The Feima Robotics SLAM200 and SLAM200E support advanced 3D visualisation workflows by enabling the creation of Gaussian Splat models from their SLAM point-cloud data and panoramic imagery. The SLAM200 has built-in panoramic cameras, and the SLAM200E has dual 12 MP panoramic cameras, so no separate camera needs to be purchased. Users can generate immersive, photorealistic 3D scenes ideal for digital twins, asset documentation and visual inspection. The SLAM200E supports large-scale 3D Gaussian Splatting generation, visualisation and application.
This workflow is completed in Feima SLAM GO POST, with the option of using third-party platforms:
- Capture the point cloud with the SLAM200 or SLAM200E while the built-in cameras record 360° imagery
- Process the scan data in SLAM GO POST to generate the point cloud and panoramic imagery
- Train the Gaussian Splat model from the captured dataset
- Export the results for third-party platforms if required, since both the outputs and the intermediate data use open formats
The result is a highly realistic, spatially accurate 3D representation that combines SLAM geometry with rich panoramic imagery. Below are several Gaussian Splat examples produced using this workflow, demonstrating the impressive quality achievable with the SLAM200 and SLAM200E.